Hugging Face Daily Papers3434
OSWAM: An efficient single-step action generation world action model
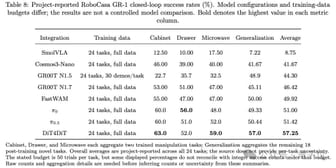
OSWAM achieves real-time high-quality action generation in autonomous driving and embodied control by using structured imagination tokens to initialize the diffusion process and distilling future condition privileged information into a single denoising step. The model generates high-quality actions with just one diffusion step, about 3 times faster than direct strategy world action models (WAM) that require dozens of denoising steps, achieving low latency of up to 40ms on an NVIDIA RTX 5090 GPU, supporting real-time compiled inference.