Heave-Ho: Decentralized Long-Horizon Multi-Humanoid Collaboration
Heave-Ho: Decentralized Long-Horizon Multi-Humanoid Collaboration
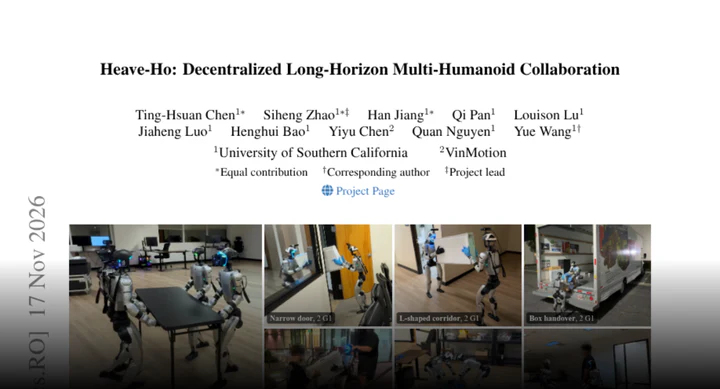
The Heave-Ho framework achieves long-term collaboration of humanoid robots through low-level multi-agent post-training and advanced visual language planning, employing a voice-based leader-follower synchronization mechanism that requires no network communication. The system, trained with two identical humanoid robots, can be scaled up to a maximum of 10 robots and generalizes without retraining in heterogeneous teams, with HH-Bench evaluations showing its continuous superiority over baseline methods.
Published on Nov 17
Authors:
,
,
,
,
,
,
,
,
Abstract
A decentralized framework enables teams of humanoids to coordinate whole-body loco-manipulation over long horizons using low-level multi-agent post-training and a high-level vision-language planner with speech-based leader-follower synchronization.
Collaboration promises to extend humanoid capabilities beyond what individual robots can achieve. However, realizing this potential requires coordinated whole-body interactions, coherent long-horizon planning, and precise synchronization across robots. We introduce Heave-Ho, a decentralized framework for long-horizon collaborative multi-humanoid loco-manipulation. At the low level, we develop a multi-agent post-training framework that adapts a humanoid foundation tracking model to physically coupled interactions between humanoids, enabling coordinated decentralized control from local observations alone. At the high level, we train a vision-language planner and design a speech-based leader-follower coordination mechanism to synchronize decentralized execution without network communication. Trained with two identical humanoids, our system scales to teams of up to ten robots and generalizes to heterogeneous teams without retraining. To benchmark these capabilities, we introduce HH-Bench, comprising 12 tasks involving teams of 2 to 10 humanoids, including heterogeneous teams. Systematic evaluations show that Heave-Ho consistently outperforms baseline methods, while real-world experiments demonstrate robust decentralized collaboration across challenging tasks.
View arXiv page View PDF Project page GitHub 8 Add to collection
Models citing this paper 0
No model linking this paper
Cite arxiv.org/abs/2611.22275 in a model README.md to link it from this page.
Datasets citing this paper 0
No dataset linking this paper
Cite arxiv.org/abs/2611.22275 in a dataset README.md to link it from this page.
Spaces citing this paper 0
No Space linking this paper
Cite arxiv.org/abs/2611.22275 in a Space README.md to link it from this page.
Collections including this paper 0
No Collection including this paper
Add this paper to a collection to link it from this page.
Source: Hugging Face Daily Papers · huggingface.co